Loading...
Searching...
No Matches
srs::App Class Reference
The primary interface class of SRS-Control. More...
#include <Application.hpp>
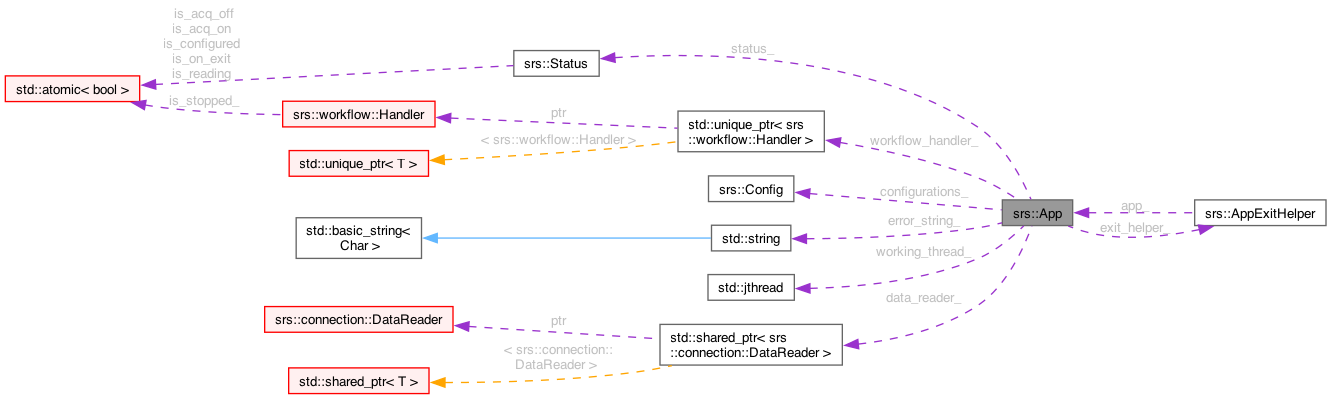
Collaboration diagram for srs::App:
Public Member Functions | |
| App (Config config) | |
| Constructor of the App class. | |
| App (const App &)=delete | |
| App (App &&)=delete | |
| App & | operator= (const App &)=delete |
| App & | operator= (App &&)=delete |
| ~App () noexcept | |
| Destructor of the App class. | |
| void | init () |
| Initialization of internal members. | |
| void | configure_fec () |
| void | switch_on () |
| Establish the communications to the available FECs to start the data acquisition. | |
| void | switch_off () |
| Establish the communications to the available FECs to stop the data acquisition. | |
| void | read_data (bool is_non_stop=true) |
| Start reading the input data stream from the port specified by srs::Config::fec_data_receive_port. If is_non_stop is true, the reading process will not be stopped until an interrupt happens, such as pressing "Ctrl-C" from users. If is_non_stop is false, the reading process will be stopped after one frame of data is read. | |
| void | start_workflow () |
| Start data analysis workflow, triggering data conversions. | |
| void | wait_for_workflow () |
| Wait for the workflow process to finish. | |
| void | set_fec_data_receiv_ports (const std::vector< int > &port_nums) |
| Set the local listen port numbers for the communications to FEC devices. | |
| void | add_fec_data_receiv_port (int port_num) |
| Add a local listen port number for the communications to FEC devices. | |
| void | set_print_mode (common::DataPrintMode mode) |
| Set the print mode. | |
| void | set_output_filenames (const std::vector< std::string > &filenames, std::size_t n_lines=1) |
| Set the output filenames. | |
| void | set_options (Config options) |
| Set the configuration values. | |
| void | set_runtime_sec (std::size_t runtime_sec) |
| Set the runtime in seconds. | |
| void | exit_and_switch_off () |
| auto | get_channel_address () const -> uint16_t |
| auto | get_io_context () -> auto & |
| auto | get_fec_strand () -> auto & |
| auto | get_workflow_handler () const -> const auto & |
| auto | get_config () const -> const auto & |
| auto | get_config_ref () -> auto & |
| auto | get_report () -> AppReport & |
| void | action_after_destructor () |
Private Types | |
| using | udp = asio::ip::udp |
| using | SwitchFutureType = std::expected<std::future<void>, std::error_code> |
| using | SwitchFutureStatusType = std::expected<std::future_status, std::error_code> |
Private Member Functions | |
| void | print_statistics () const |
| void | init_spdlog () |
| void | wait_for_reading_finish () |
| void | set_remote_fec_endpoints () |
| void | set_cancel_method () |
| void | add_remote_fec_endpoint (std::string_view remote_ip, int port_number) |
| template<typename T> | |
| auto | switch_FECs (std::string_view connection_name) -> SwitchFutureType |
| auto | check_port_number_validity () -> bool |
Static Private Member Functions | |
| static auto | wait_for_switch_action (const SwitchFutureType &switch_future) -> SwitchFutureStatusType |
Private Attributes | |
| uint16_t | channel_address_ = common::DEFAULT_CHANNEL_ADDRE |
| Config | config_ |
| std::unique_ptr< AppReport > | report_ |
| io_context_type | io_context_ { 4 } |
| Asio io_context that manages the task scheduling and network IO. | |
| std::size_t | runtime_sec_ {} |
| Time duration (seconds) to stop the application. If value is zero, the application is in non-stop mode and must be stopped by pressing Ctrl-C. | |
| asio::executor_work_guard< io_context_type::executor_type > | io_work_guard_ |
| Asio io_context work guard. | |
| std::vector< udp::endpoint > | remote_fec_endpoints_ |
| Remote endpoints of FEC devices. | |
| asio::signal_set | signal_set_ { io_context_, SIGINT, SIGTERM } |
| User signal handler for interrupts. | |
| asio::steady_timer | cancel_timer_ { io_context_ } |
| Cancelling timer. | |
| asio::strand< io_context_type::executor_type > | fec_strand_ |
| FEC communication strand for synchronous communications. | |
| std::jthread | working_thread_ |
| Main working thread. | |
| std::jthread | workflow_thread_ |
| Main thread to run workflow. | |
| SwitchFutureType | switch_on_future_ |
| SwitchFutureType | switch_off_future_ |
| internal::AppExitHelper | exit_helper_ { this } |
| Exit helper for App class. This is called after calling the destructor. | |
| std::unique_ptr< workflow::AnalysisHandle > | workflow_handler_ |
| The handler to the analysis working flow. | |
| std::vector< std::shared_ptr< connection::DataSocket > > | data_sockets_ |
| Communication to the main input data stream. | |
Detailed Description
The primary interface class of SRS-Control.
Application class should be instantiated only once during the whole program. Public setter methods should be called before calling the init() method.
Definition at line 81 of file Application.hpp.
Member Typedef Documentation
◆ SwitchFutureStatusType
|
private |
Definition at line 218 of file Application.hpp.
◆ SwitchFutureType
|
private |
Definition at line 217 of file Application.hpp.
◆ udp
|
private |
Definition at line 216 of file Application.hpp.
Constructor & Destructor Documentation
◆ App() [1/3]
| srs::App::App | ( | Config | config | ) |
Constructor of the App class.
The constructor contains following actions:
- Instantiation of the work guard, which make sure the io_context_ keep accepting new tasks.
- Instantiation of strand from the io_context_, which synchronizes the communications among the FECs.
- Set the logging format.
- Instantiation (memory allocation) of workflow_handler_.
Definition at line 83 of file Application.cpp.
◆ App() [2/3]
|
delete |
◆ App() [3/3]
|
delete |
◆ ~App()
|
noexcept |
Destructor of the App class.
This destructor is called before the destruction of each members. The destructor contains following actions:
- Cancel the signal_set_.
- Wait for the Status::is_reading to be false, which will be unset from connection::DataReader::close(). The waiting time is set to be common::DEFAULT_STATUS_WAITING_TIME_SECONDS.
- Requesting acquisition off to all FEC devices.
- Set the Status::is_acq_on to be true.
The exit process of App class also contains the destruction of its member variables. The following order must be kept:
- Destruction of connection::DataReader member.
- Destruction of workflow::Handler member.
- Destruction of internal::AppExitHelper member, which calls end_of_work method.
- Destruction of working_thread_ (std::jthread) by waiting for the thread to finish.
- Destruction other members. Orders are not important.
- Destruction of io_context member. This must be done in the very end.
- See also
- internal::AppExitHelper
Definition at line 125 of file Application.cpp.
Member Function Documentation
◆ action_after_destructor()
| void srs::App::action_after_destructor | ( | ) |
Definition at line 92 of file Application.cpp.
◆ add_fec_data_receiv_port()
|
inline |
Add a local listen port number for the communications to FEC devices.
Definition at line 176 of file Application.hpp.
◆ add_remote_fec_endpoint()
|
private |
Definition at line 271 of file Application.cpp.
◆ check_port_number_validity()
|
private |
Definition at line 315 of file Application.cpp.
◆ configure_fec()
|
inline |
Definition at line 129 of file Application.hpp.
◆ exit_and_switch_off()
| void srs::App::exit_and_switch_off | ( | ) |
Definition at line 223 of file Application.cpp.
◆ get_channel_address()
|
inlinenodiscard |
Definition at line 204 of file Application.hpp.
◆ get_config()
|
inlinenodiscard |
Definition at line 208 of file Application.hpp.
◆ get_config_ref()
|
inlinenodiscard |
Definition at line 209 of file Application.hpp.
◆ get_fec_strand()
|
inlinenodiscard |
Definition at line 206 of file Application.hpp.
◆ get_io_context()
|
inlinenodiscard |
Definition at line 205 of file Application.hpp.
◆ get_report()
|
inlinenodiscard |
Definition at line 210 of file Application.hpp.
◆ get_workflow_handler()
|
inlinenodiscard |
Definition at line 207 of file Application.hpp.
◆ init()
| void srs::App::init | ( | ) |
Initialization of internal members.
Definition at line 175 of file Application.cpp.
◆ init_spdlog()
|
private |
Definition at line 48 of file Application.cpp.
◆ operator=() [1/2]
◆ operator=() [2/2]
◆ print_statistics()
|
private |
Definition at line 132 of file Application.cpp.
◆ read_data()
| void srs::App::read_data | ( | bool | is_non_stop = true | ) |
Start reading the input data stream from the port specified by srs::Config::fec_data_receive_port. If is_non_stop is true, the reading process will not be stopped until an interrupt happens, such as pressing "Ctrl-C" from users. If is_non_stop is false, the reading process will be stopped after one frame of data is read.
- Parameters
-
is_non_stop Flag to set non-stop mode.
Definition at line 330 of file Application.cpp.
◆ set_cancel_method()
|
private |
Definition at line 140 of file Application.cpp.
◆ set_fec_data_receiv_ports()
|
inline |
Set the local listen port numbers for the communications to FEC devices.
Definition at line 168 of file Application.hpp.
◆ set_options()
|
inline |
Set the configuration values.
Definition at line 191 of file Application.hpp.
◆ set_output_filenames()
| void srs::App::set_output_filenames | ( | const std::vector< std::string > & | filenames, |
| std::size_t | n_lines = 1 ) |
Set the output filenames.
Definition at line 265 of file Application.cpp.
◆ set_print_mode()
| void srs::App::set_print_mode | ( | common::DataPrintMode | mode | ) |
Set the print mode.
Definition at line 264 of file Application.cpp.
◆ set_remote_fec_endpoints()
|
private |
Definition at line 384 of file Application.cpp.
◆ set_runtime_sec()
|
inline |
Set the runtime in seconds.
Definition at line 196 of file Application.hpp.
◆ start_workflow()
| void srs::App::start_workflow | ( | ) |
Start data analysis workflow, triggering data conversions.
This function call is executed in the main thread.
Definition at line 357 of file Application.cpp.
◆ switch_FECs()
template<typename T>
|
private |
Definition at line 286 of file Application.cpp.
◆ switch_off()
| void srs::App::switch_off | ( | ) |
Establish the communications to the available FECs to stop the data acquisition.
Definition at line 309 of file Application.cpp.
◆ switch_on()
| void srs::App::switch_on | ( | ) |
Establish the communications to the available FECs to start the data acquisition.
Definition at line 307 of file Application.cpp.
◆ wait_for_reading_finish()
|
private |
Definition at line 203 of file Application.cpp.
◆ wait_for_switch_action()
|
staticprivate |
Definition at line 367 of file Application.cpp.
◆ wait_for_workflow()
|
inline |
Wait for the workflow process to finish.
Definition at line 162 of file Application.hpp.
Member Data Documentation
◆ cancel_timer_
|
private |
Cancelling timer.
Definition at line 250 of file Application.hpp.
◆ channel_address_
|
private |
Definition at line 220 of file Application.hpp.
◆ config_
|
private |
Definition at line 221 of file Application.hpp.
◆ data_sockets_
|
private |
Communication to the main input data stream.
Definition at line 282 of file Application.hpp.
◆ exit_helper_
|
private |
Exit helper for App class. This is called after calling the destructor.
Definition at line 272 of file Application.hpp.
◆ fec_strand_
|
private |
FEC communication strand for synchronous communications.
Definition at line 254 of file Application.hpp.
◆ io_context_
|
private |
Asio io_context that manages the task scheduling and network IO.
Definition at line 229 of file Application.hpp.
◆ io_work_guard_
|
private |
Asio io_context work guard.
Definition at line 238 of file Application.hpp.
◆ remote_fec_endpoints_
|
private |
Remote endpoints of FEC devices.
Definition at line 242 of file Application.hpp.
◆ report_
|
private |
Definition at line 225 of file Application.hpp.
◆ runtime_sec_
|
private |
Time duration (seconds) to stop the application. If value is zero, the application is in non-stop mode and must be stopped by pressing Ctrl-C.
Definition at line 234 of file Application.hpp.
◆ signal_set_
|
private |
User signal handler for interrupts.
Definition at line 246 of file Application.hpp.
◆ switch_off_future_
|
private |
Definition at line 266 of file Application.hpp.
◆ switch_on_future_
|
private |
Definition at line 264 of file Application.hpp.
◆ workflow_handler_
|
private |
The handler to the analysis working flow.
Definition at line 276 of file Application.hpp.
◆ workflow_thread_
|
private |
Main thread to run workflow.
Definition at line 262 of file Application.hpp.
◆ working_thread_
|
private |
Main working thread.
Definition at line 258 of file Application.hpp.
The documentation for this class was generated from the following files:
- backend/srs/Application.hpp
- backend/srs/Application.cpp
